RoboticsPart 1 of 2Drawing 3.1 of 37
The machine
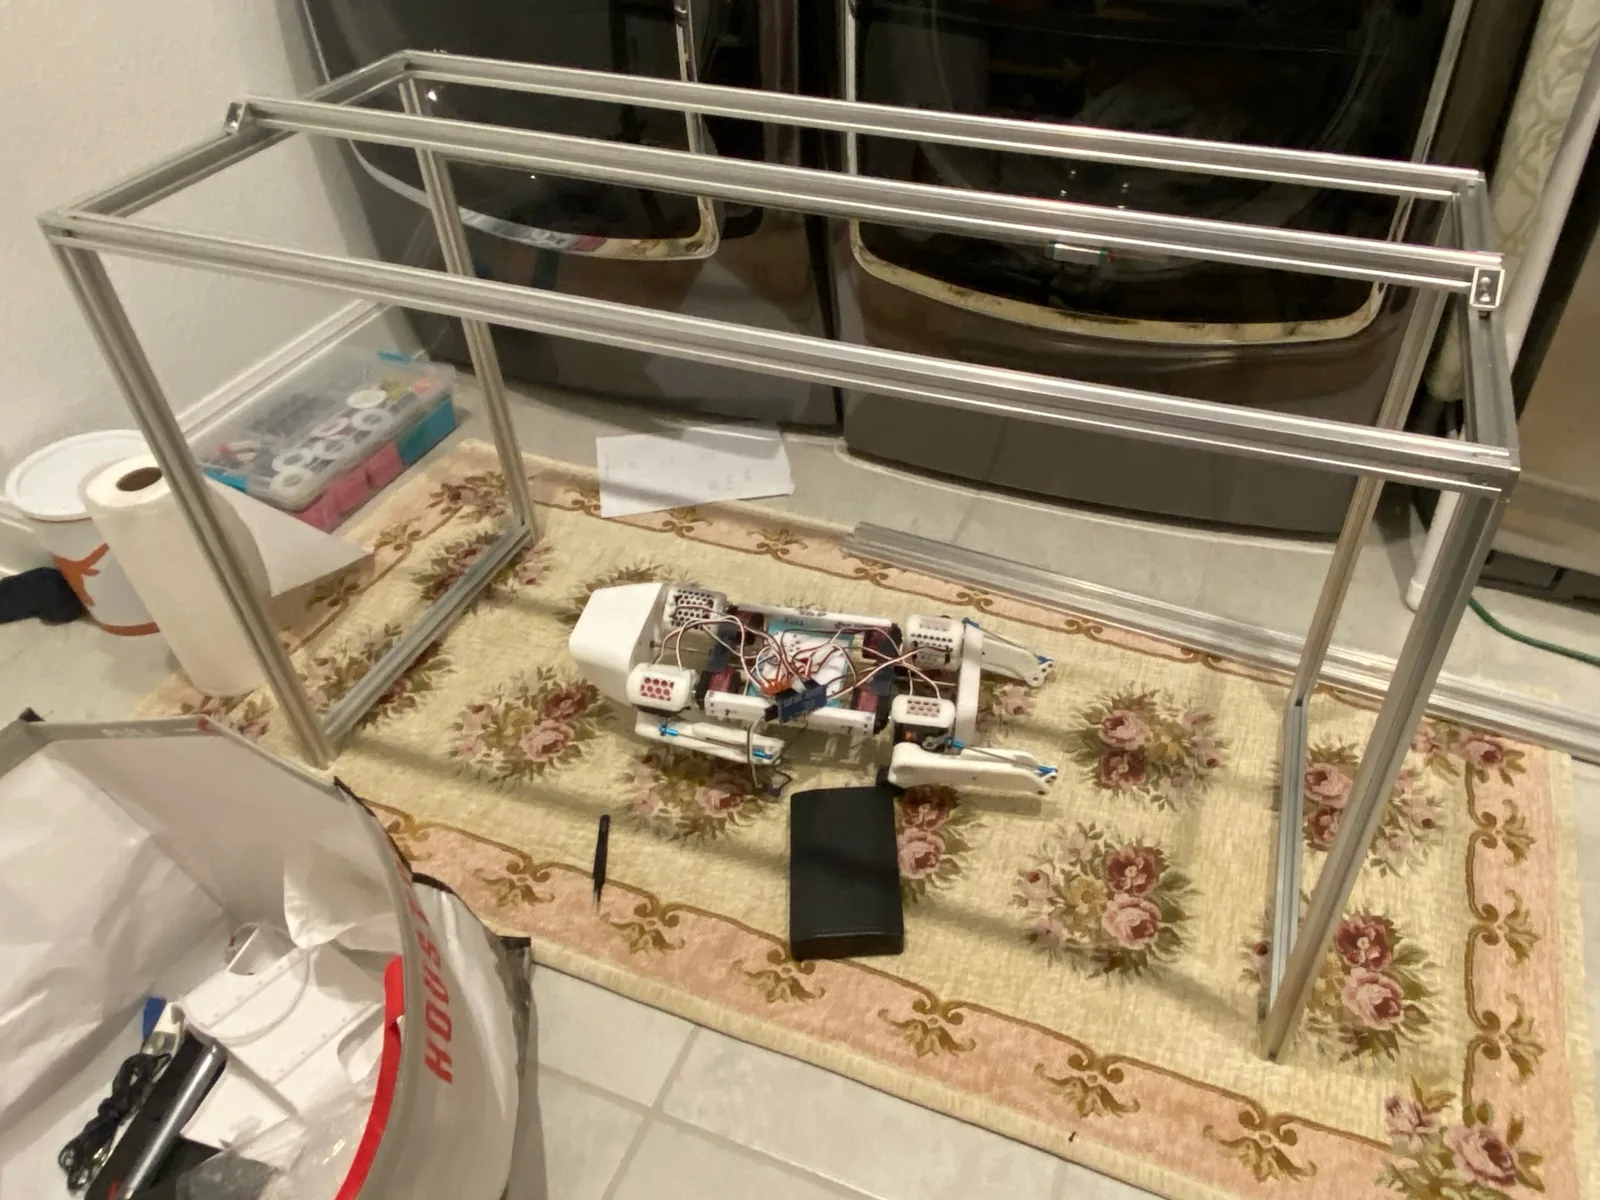
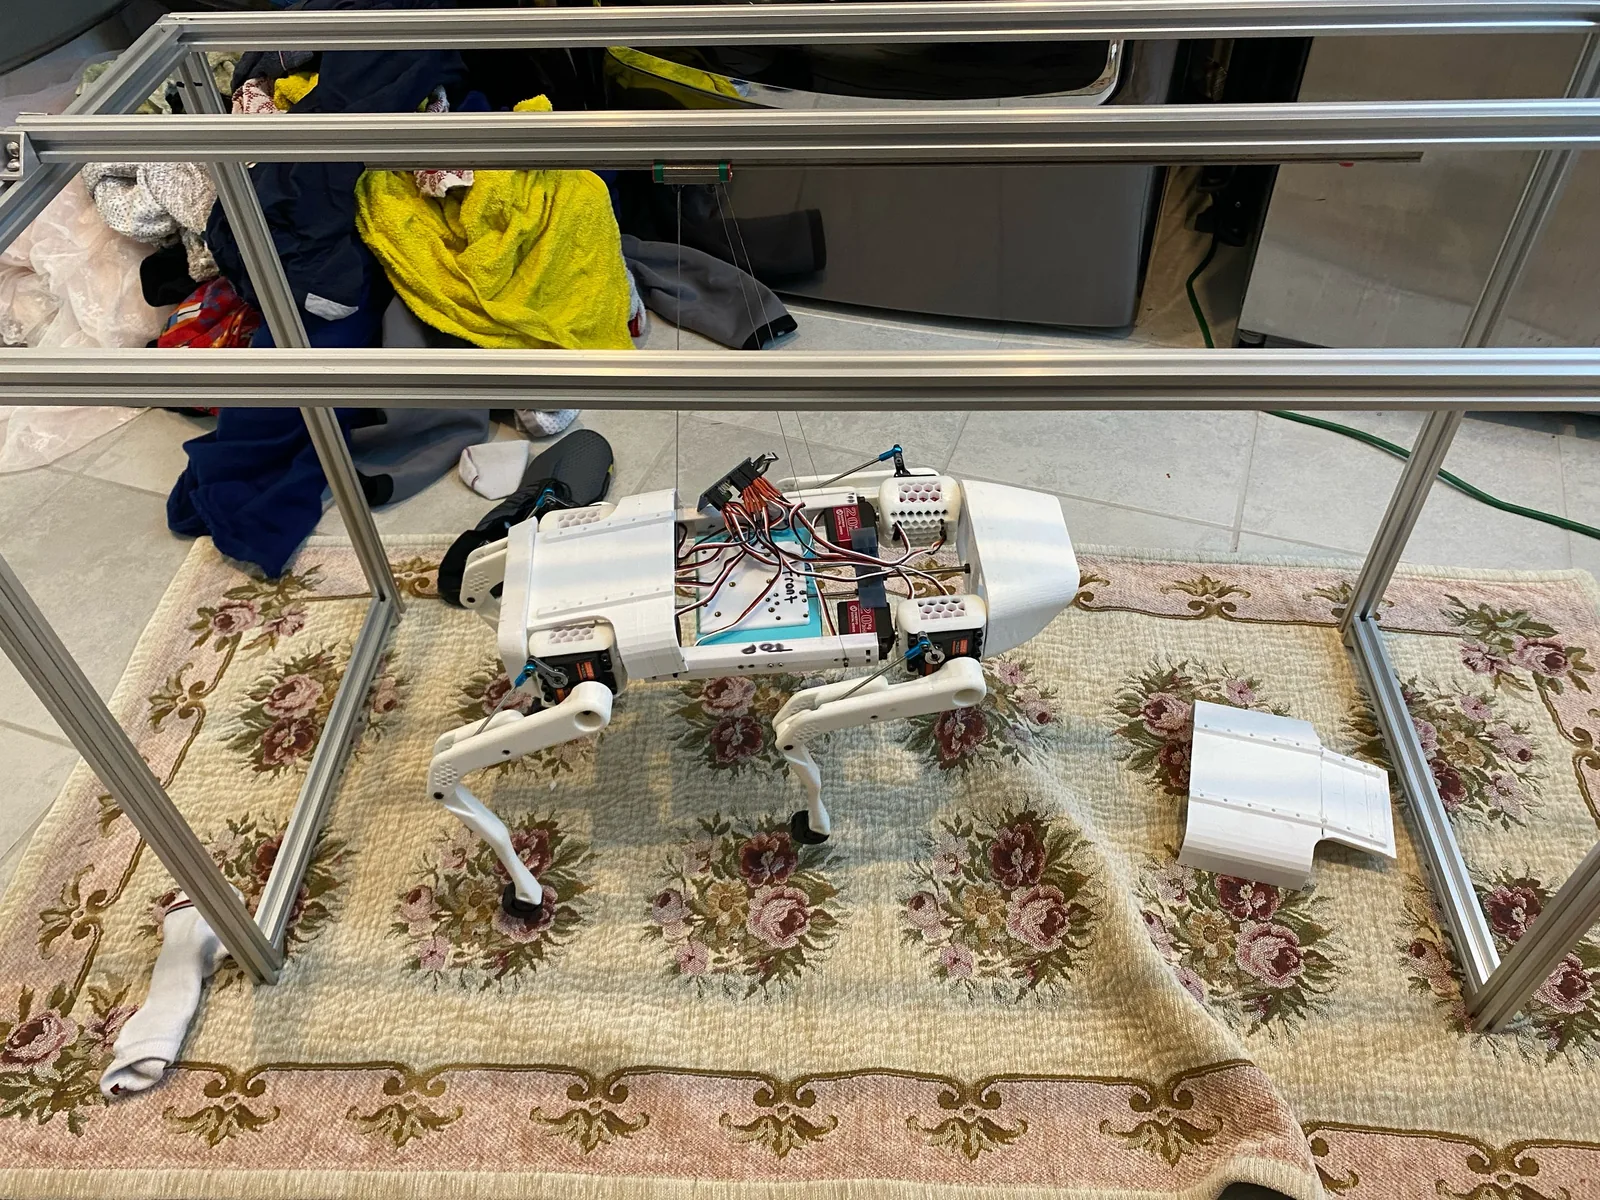
Twelve joints on a printed chassis, with the knees driven through pushrods. Emin Alp Arslan and I designed and built it across 2021 and 2022, and it's been apart on a shelf since.
- StatusComplete, September 2026. Robot built 2021 to 2022, software rebuilt from scratch from August 2026
- Joints12 servos, three per leg, 1.96 N.m each
- Mass3.1 kg
- BrainRaspberry Pi, PWM at 50 Hz, three IMUs on the trunk
Sheet 02 of 03/The machine
What the robot is
Only four of the twelve servos sit in the body. The rest are in the hip modules and drive the knees through a pushrod, so a servo's angle is never the same as the knee's angle. That layout got guessed wrong twice from photos and CAD before it was finally written down.
Sheet 03 of 03/Building it
Printing and assembling it
We printed the chassis and legs and wired the twelve servos into one driver board. We also built a handheld controller with two thumbsticks.