RoboticsDrawing 3 of 47
Gray
quadruped
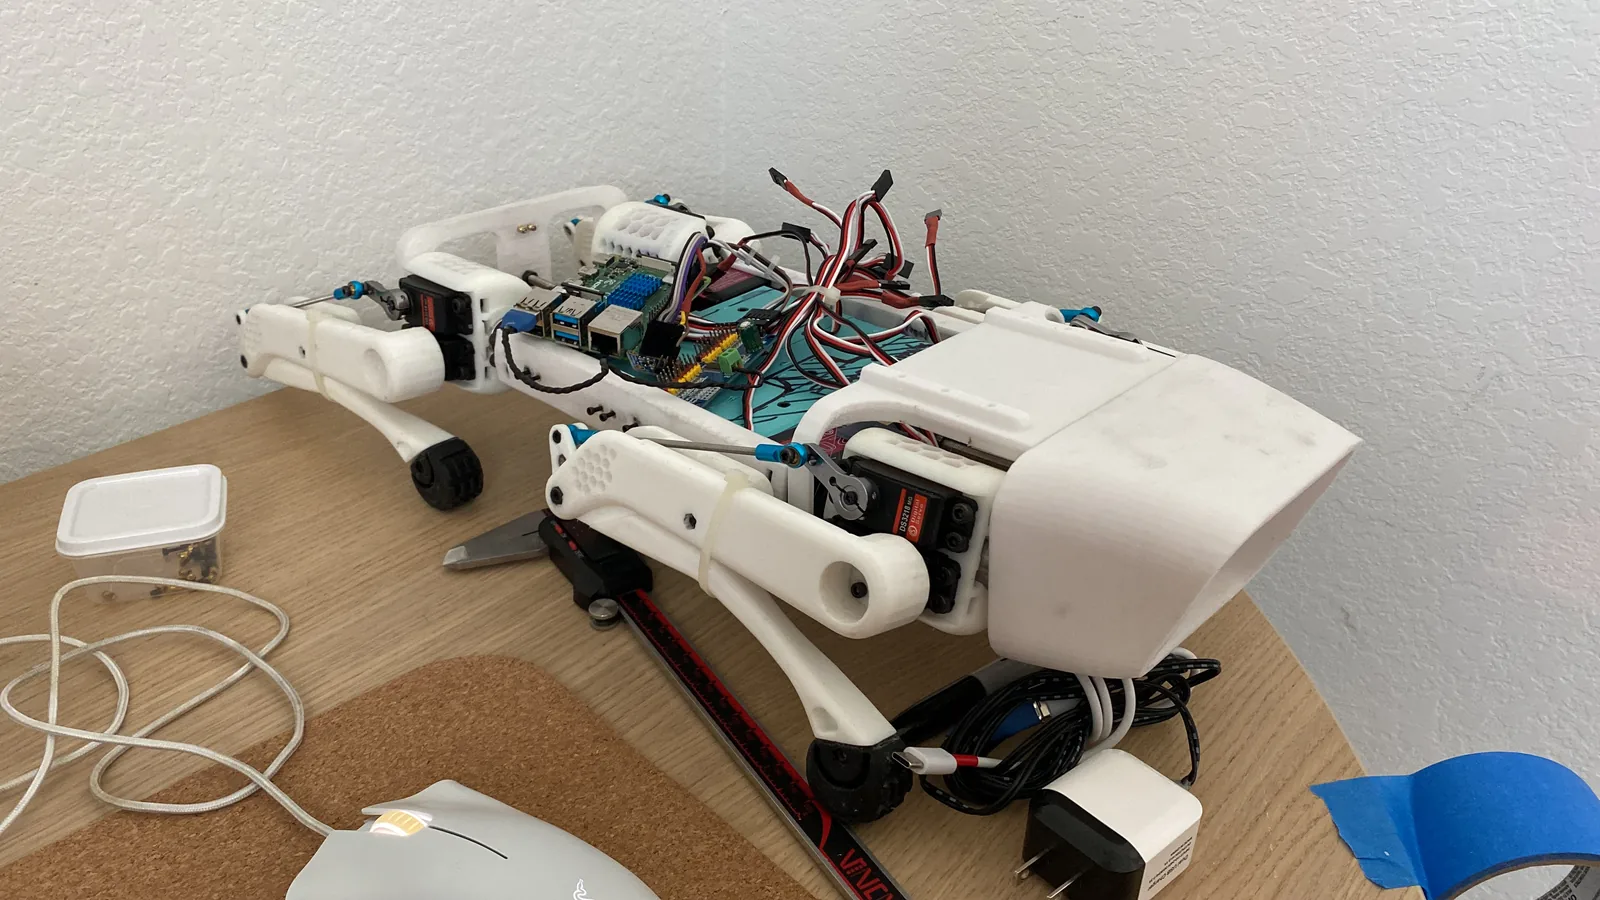
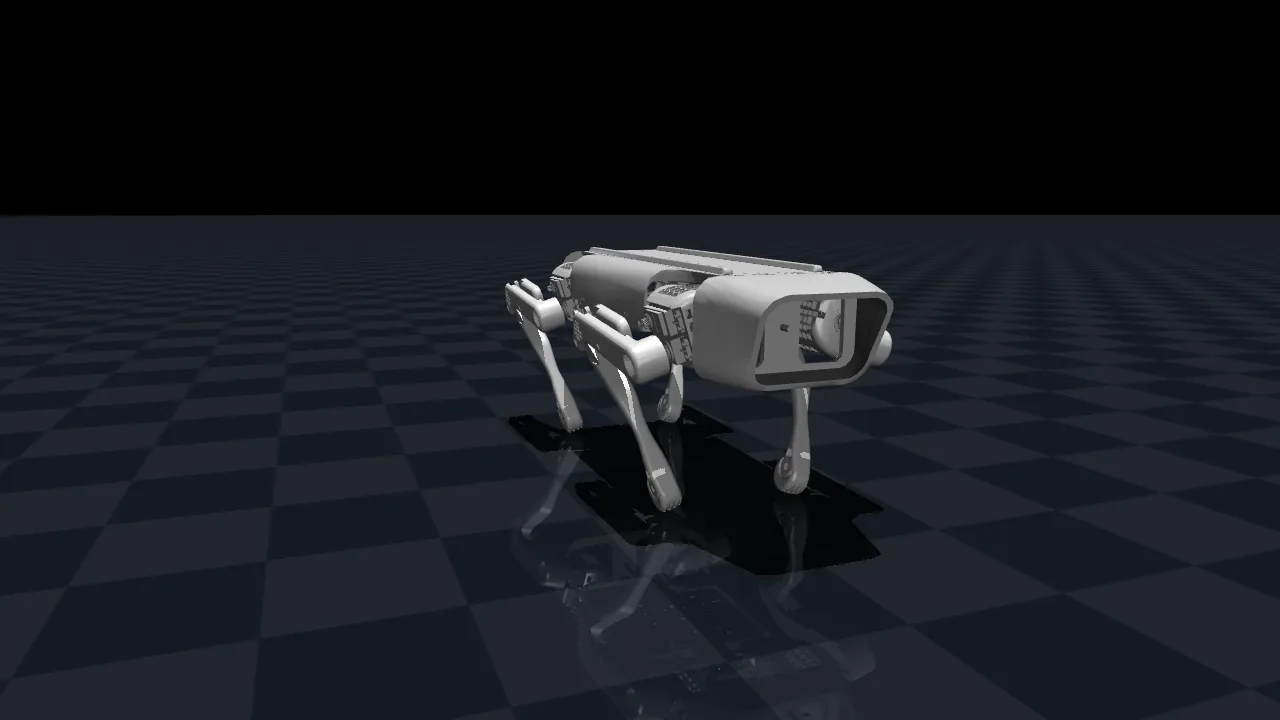
Gray is a 12-joint quadruped robot that a friend and I built in 2021 and 2022. I taught it to walk in simulation, then stopped building this version because its hobby servos hold it back. Next I want to build Gray 2.0 with better motors.
- StatusComplete, September 2026. Robot built 2021 to 2022, software rebuilt from scratch from August 2026
- Joints12 servos, three per leg, 1.96 N.m each
- Mass3.1 kg
- BrainRaspberry Pi, PWM at 50 Hz, three IMUs on the trunk
Sheet 02 of 05/Takeaways
Why I stopped and what I learned
I worked on Gray for a long time and got further than I expected. I rebuilt the whole software stack and taught it to walk in simulation, and then I decided to stop building this version.
The servos are what hold it back. A hobby servo only takes a position. It can't sense or control force, and I don't think it can survive the impacts a trot puts through it. Every policy I train is limited by that, and I don't see a reason to finish a robot dog with joints that weak.
Things I learned from it:
- Writing reward functions and tuning them until the walk came out right
- Setting up a reinforcement learning pipeline and getting it to train fast on limited hardware, with 64 robots at once
- Building the simulation from accurate CAD, because the policy only learns the robot it's given
- Checking each policy against a list of pass or fail criteria
- Training separate policies for flat ground and for slopes
Next I want to build Gray 2.0. It'll use the same learning setup and reward functions on a new quadruped with quasi-direct-drive actuators. Those are brushless motors with a low-ratio planetary gearbox, the same kind of joint the MIT Mini Cheetah uses. They can control torque directly, they can be back-driven, and they handle impacts much better than servos.

Sheet 03 of 05/Parts
Issued as separate drawings
I split this project into parts. Each part below has its own page, with its own sections and pictures.
Part 01 / 02
The machine
Twelve joints on a printed chassis, with the knees driven through pushrods. Emin Alp Arslan and I designed and built it across 2021 and 2022, and it's been apart on a shelf since.
Part 02 / 02
Learning to walk
A policy I've trained in simulation since August 2026. This part covers what it can do, the three things that broke getting there, and why none of it has been on the robot.
Sheet 04 of 05/Play
Drive it yourself
Soon you'll be able to control the robot yourself, right here on this page.
The frame below is where it will go. It's a work in progress.